Where I Can Contribute
Motion Planning & Reachability
Workspace analysis, trajectory generation, and constrained motion planning.Manipulation & Control
Force-aware manipulation, motion execution, and contact-rich tasks.ROS 2 & C++ Development
Robotics software development, integration, and troubleshooting.Simulation & Validation
Robot simulation, trajectory testing, and software verification.
Selected Robotics Projects
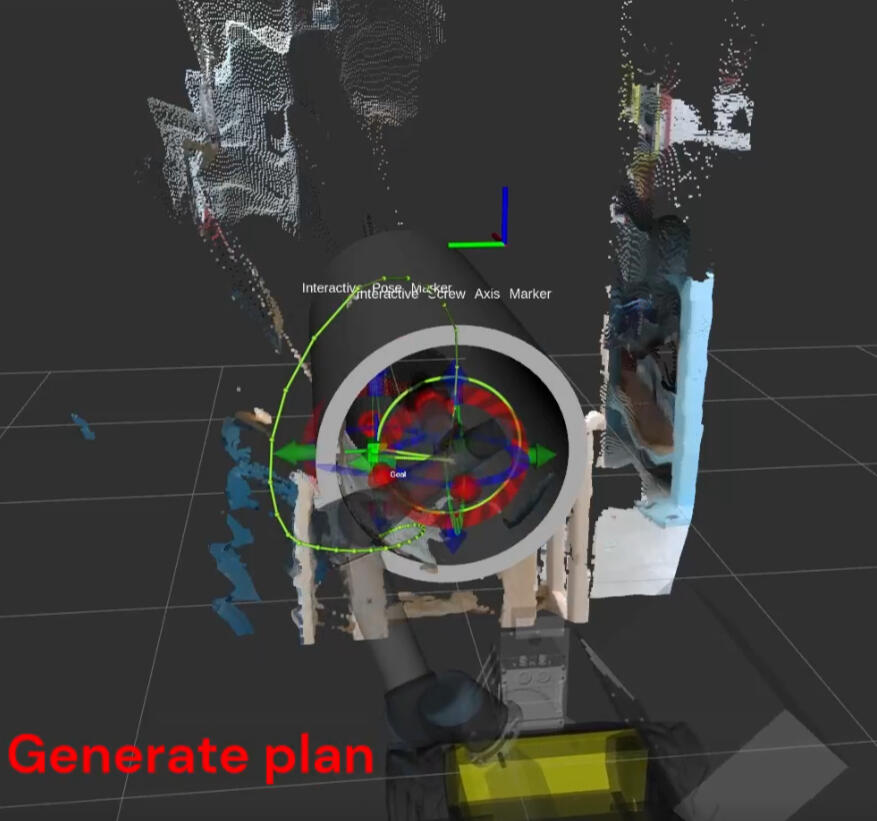
Supervised Autonomy for Robotic Manipulation in a Pipe
Developed motion planning, control, and execution software for robotic contact tasks inside a pipe, including full 360-degree tool motion in a constrained workspace.The system combined screw-based planning, point cloud data, force-aware control, and supervised execution on physical robot hardware.
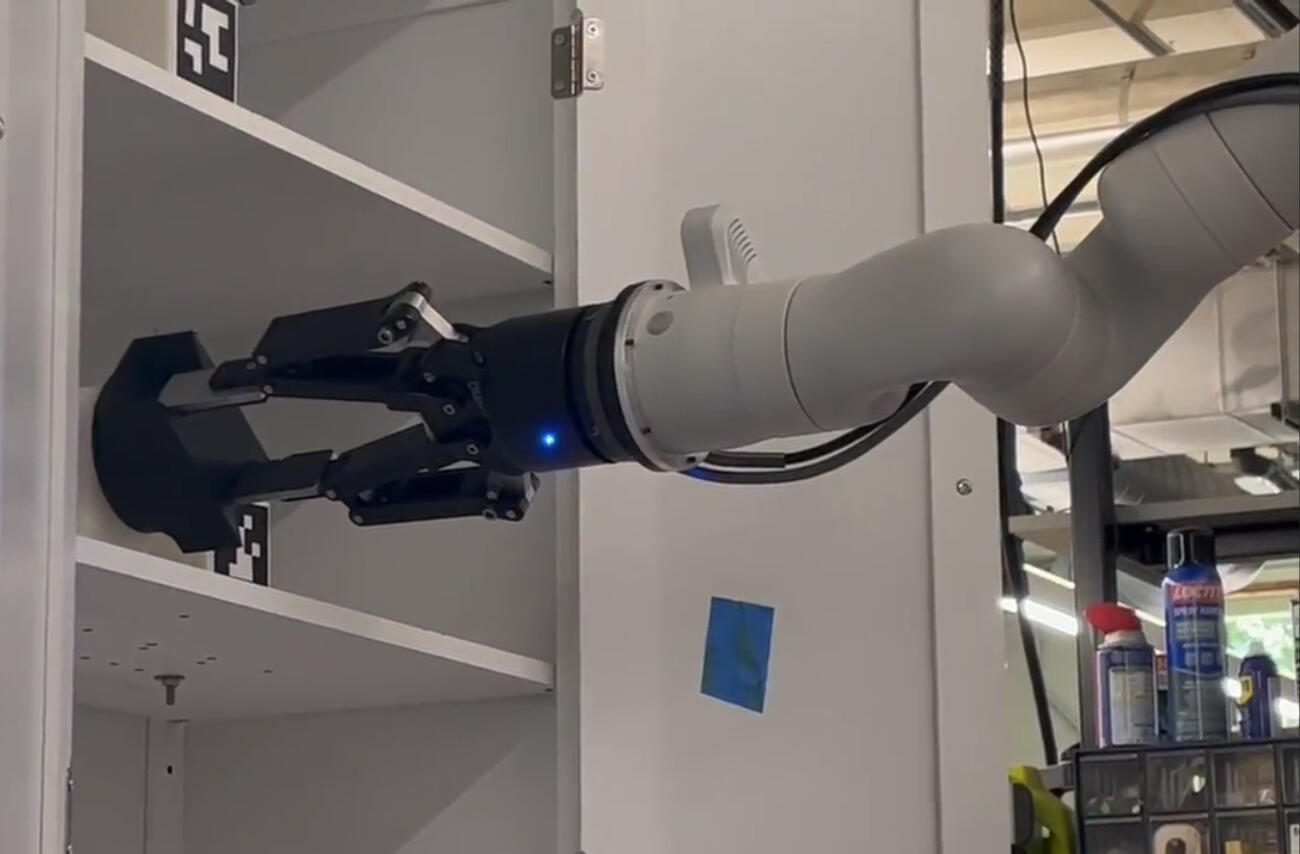
Robotic Servicing for Space Applications
A semi-autonomous robotic manipulation project using MoveIt Pro, perception, and force-aware control for space-servicing tasks.The system combined next-best-view planning, AprilTag-based object localization, and manipulation routines for opening doors, retrieving objects, cutting tape, and handling a fuel cap.
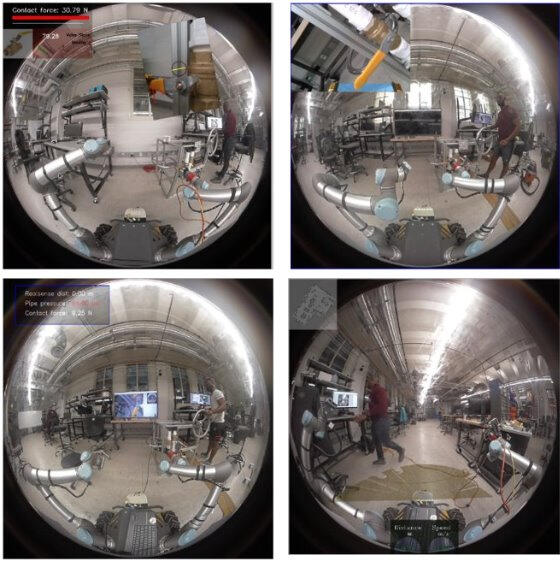
Valve Manipulation with InSitu, IoRT, and Screw Primitives
A mobile manipulation demonstration combining the InSitu situational awareness framework, networked robot interfaces, and screw-based motion primitives.The system demonstrated remote robot positioning and valve manipulation while the operator supervised the task from outside the robot's direct line of sight.
Additional Projects & Demonstrations
About Me
I'm Emmanuel Akita, a robotics software engineer with a Ph.D. in Mechanical Engineering from the University of Texas at Austin.My work focuses on robotic manipulation, motion planning, controls, and supervised autonomy. I've developed and tested software on industrial robot arms and mobile manipulators, working with C++, Python, ROS 2, and physical robot systems.I'm particularly interested in how robots can operate reliably in complex environments, combining model-based planning and control with perception, force feedback, and physical interaction. My broader research interests include embodied AI and how learning-based methods can complement classical approaches to robotic autonomy.I'm open to full-time robotics software opportunities, technical collaborations, and selected project-based work.
Work With Me
Through Akita Robotics Studio, I offer project-based robotics software support to robotics teams and system integrators. My focus includes motion planning, manipulation, controls, simulation, and robot software integration. I primarily work remotely, with planned onsite support when a project requires it.If you have a robotics software problem where my experience could be useful, feel free to get in touch.